All Formats & Editions
1 - 1 of 1 results found
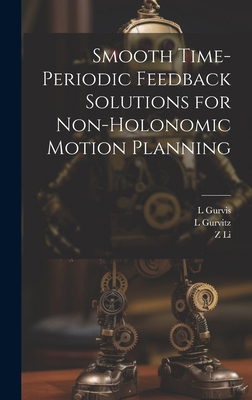
Smooth Time-periodic Feedback Solutions for Non...
Edition Description
This book presents a comprehensive study of feedback control for non-holonomic systems in time periodic environments. The authors introduce new control designs for stabilization, trajectory tracking and disturbance rejection in a time periodic setting, with applications to...
Edition Details
Format:Hardcover
Language:English
ISBN:1019941863
Format: Hardcover
Condition:
$
29.95
Copyright © 2026 Thriftbooks.com
Terms of Use | Privacy Policy | Do Not Sell/Share My Personal Information | Cookie Policy | Cookie Preferences | Accessibility Statement
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC