All Formats & Editions
1 - 1 of 1 results found
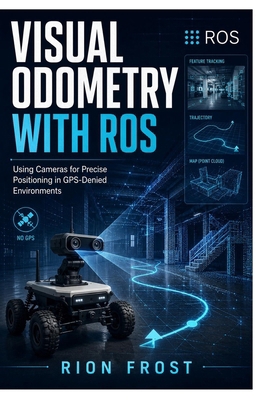
Visual Odometry with ROS: Using Cameras for Pre...
By RION FROST
Edition Description
Visual Odometry with ROS is a practical guide to using cameras for precise positioning in GPS-denied environments. This book explains how visual odometry helps robots estimate movement, track position, and support navigation when GPS is weak, unavailable, or unreliable...
Edition Details
Format:Paperback
Language:English
ISBN:B0H82MSHFC
Format: Paperback
Condition:
$
19.99
Copyright © 2026 Thriftbooks.com
Terms of Use | Privacy Policy | Do Not Sell/Share My Personal Information | Cookie Notice | Cookie Preferences | Accessibility Statement
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC