Mobile Robot Systems for Human Hand Emulation
No Customer Reviews

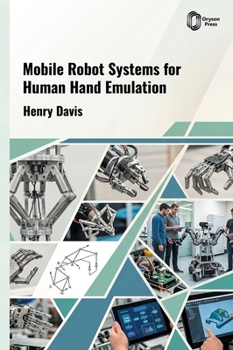
Mobile Robot Systems for Human Hand Emulation explores the critical domain of advanced robotics, focusing on parallel manipulators. These systems are pivotal for achieving high precision, dexterity, and reconfigurability in complex tasks, ranging from large-scale scientific instruments to intricate biological emulation. A core challenge lies in designing and optimizing robotic architectures that can dynamically adapt and perform with human-like agility and functional versatility. This book delves into the fundamental principles, design methodologies, and diverse applications of parallel mechanisms. It covers detailed kinematic and accuracy analyses of supporting structures, the architectural design and optimization of reconfigurable parallel robots, and the development of novel manipulators. Specific applications include their use in large-scale scientific projects like the FAST active reflector and ITER assembly, alongside innovative approaches to modeling the human hand as a parallel manipulator and creating feasible human spine motion simulators. This comprehensive resource is essential for researchers, graduate students, and professionals in robotics, mechanical engineering, biomechanics, and related fields seeking to advance the design and application of parallel manipulator systems.
Format:Hardcover
Language:English
ISBN:B0HN2QY7PS
ISBN13:9798902112006
Release Date:August 2026
Publisher:Orysonpress
Length:408 Pages
Weight:2.03 lbs.
Dimensions:0.9" x 7.0" x 10.0"
Customer Reviews
0 rating
Copyright © 2026 Thriftbooks.com
Terms of Use | Privacy Policy | Do Not Sell/Share My Personal Information | Cookie Notice | Cookie Preferences | Accessibility Statement
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC
ThriftBooks ® and the ThriftBooks ® logo are registered trademarks of Thrift Books Global, LLC